|
Chenyang Shi I'm an undergraduate student at Shanghai Jiao Tong University, School of Computer Science, majoring in Software Engineering. Email / Github / Google Scholar / Twitter (X) |
|
PublicationsSelected publications and research projects. |
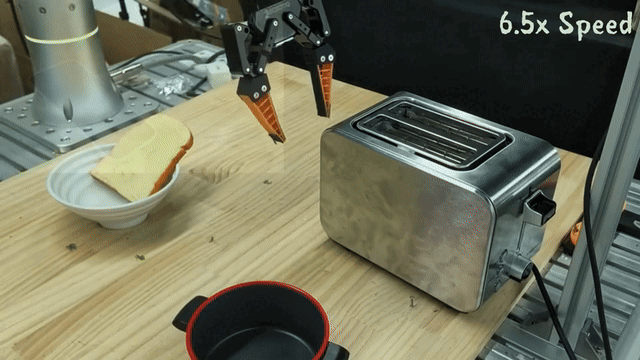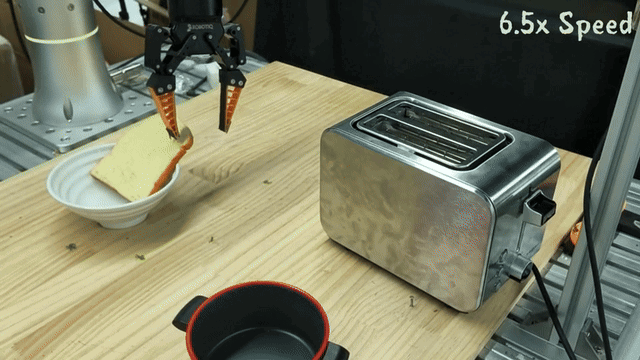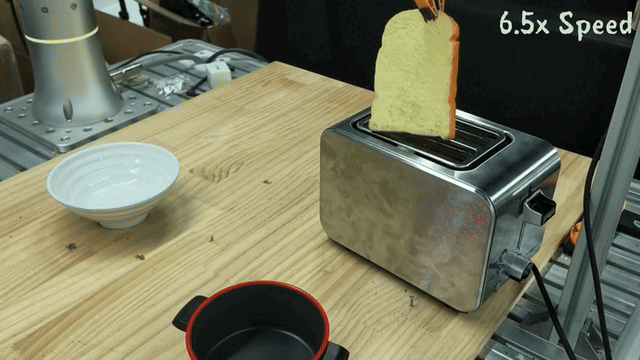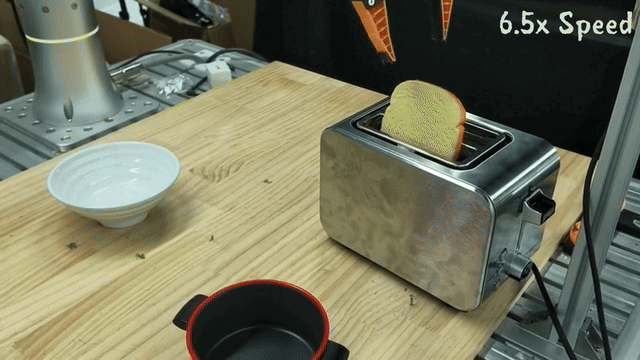 |
RoboPrompt: Intuitive Robot Policy Steering with Sparse Human Input
Yanwen Zou, Chenyang Shi, Guoxuan Xu, Wenye Yu, Wendi Chen, Ye Pan, Cewu Lu†, Chuan Wen† arXiv, 2026 project page / arXiv RoboPrompt lets users steer diffusion and flow-matching robot policies with sparse target points, drawn traces, and coarse directional guidance. |
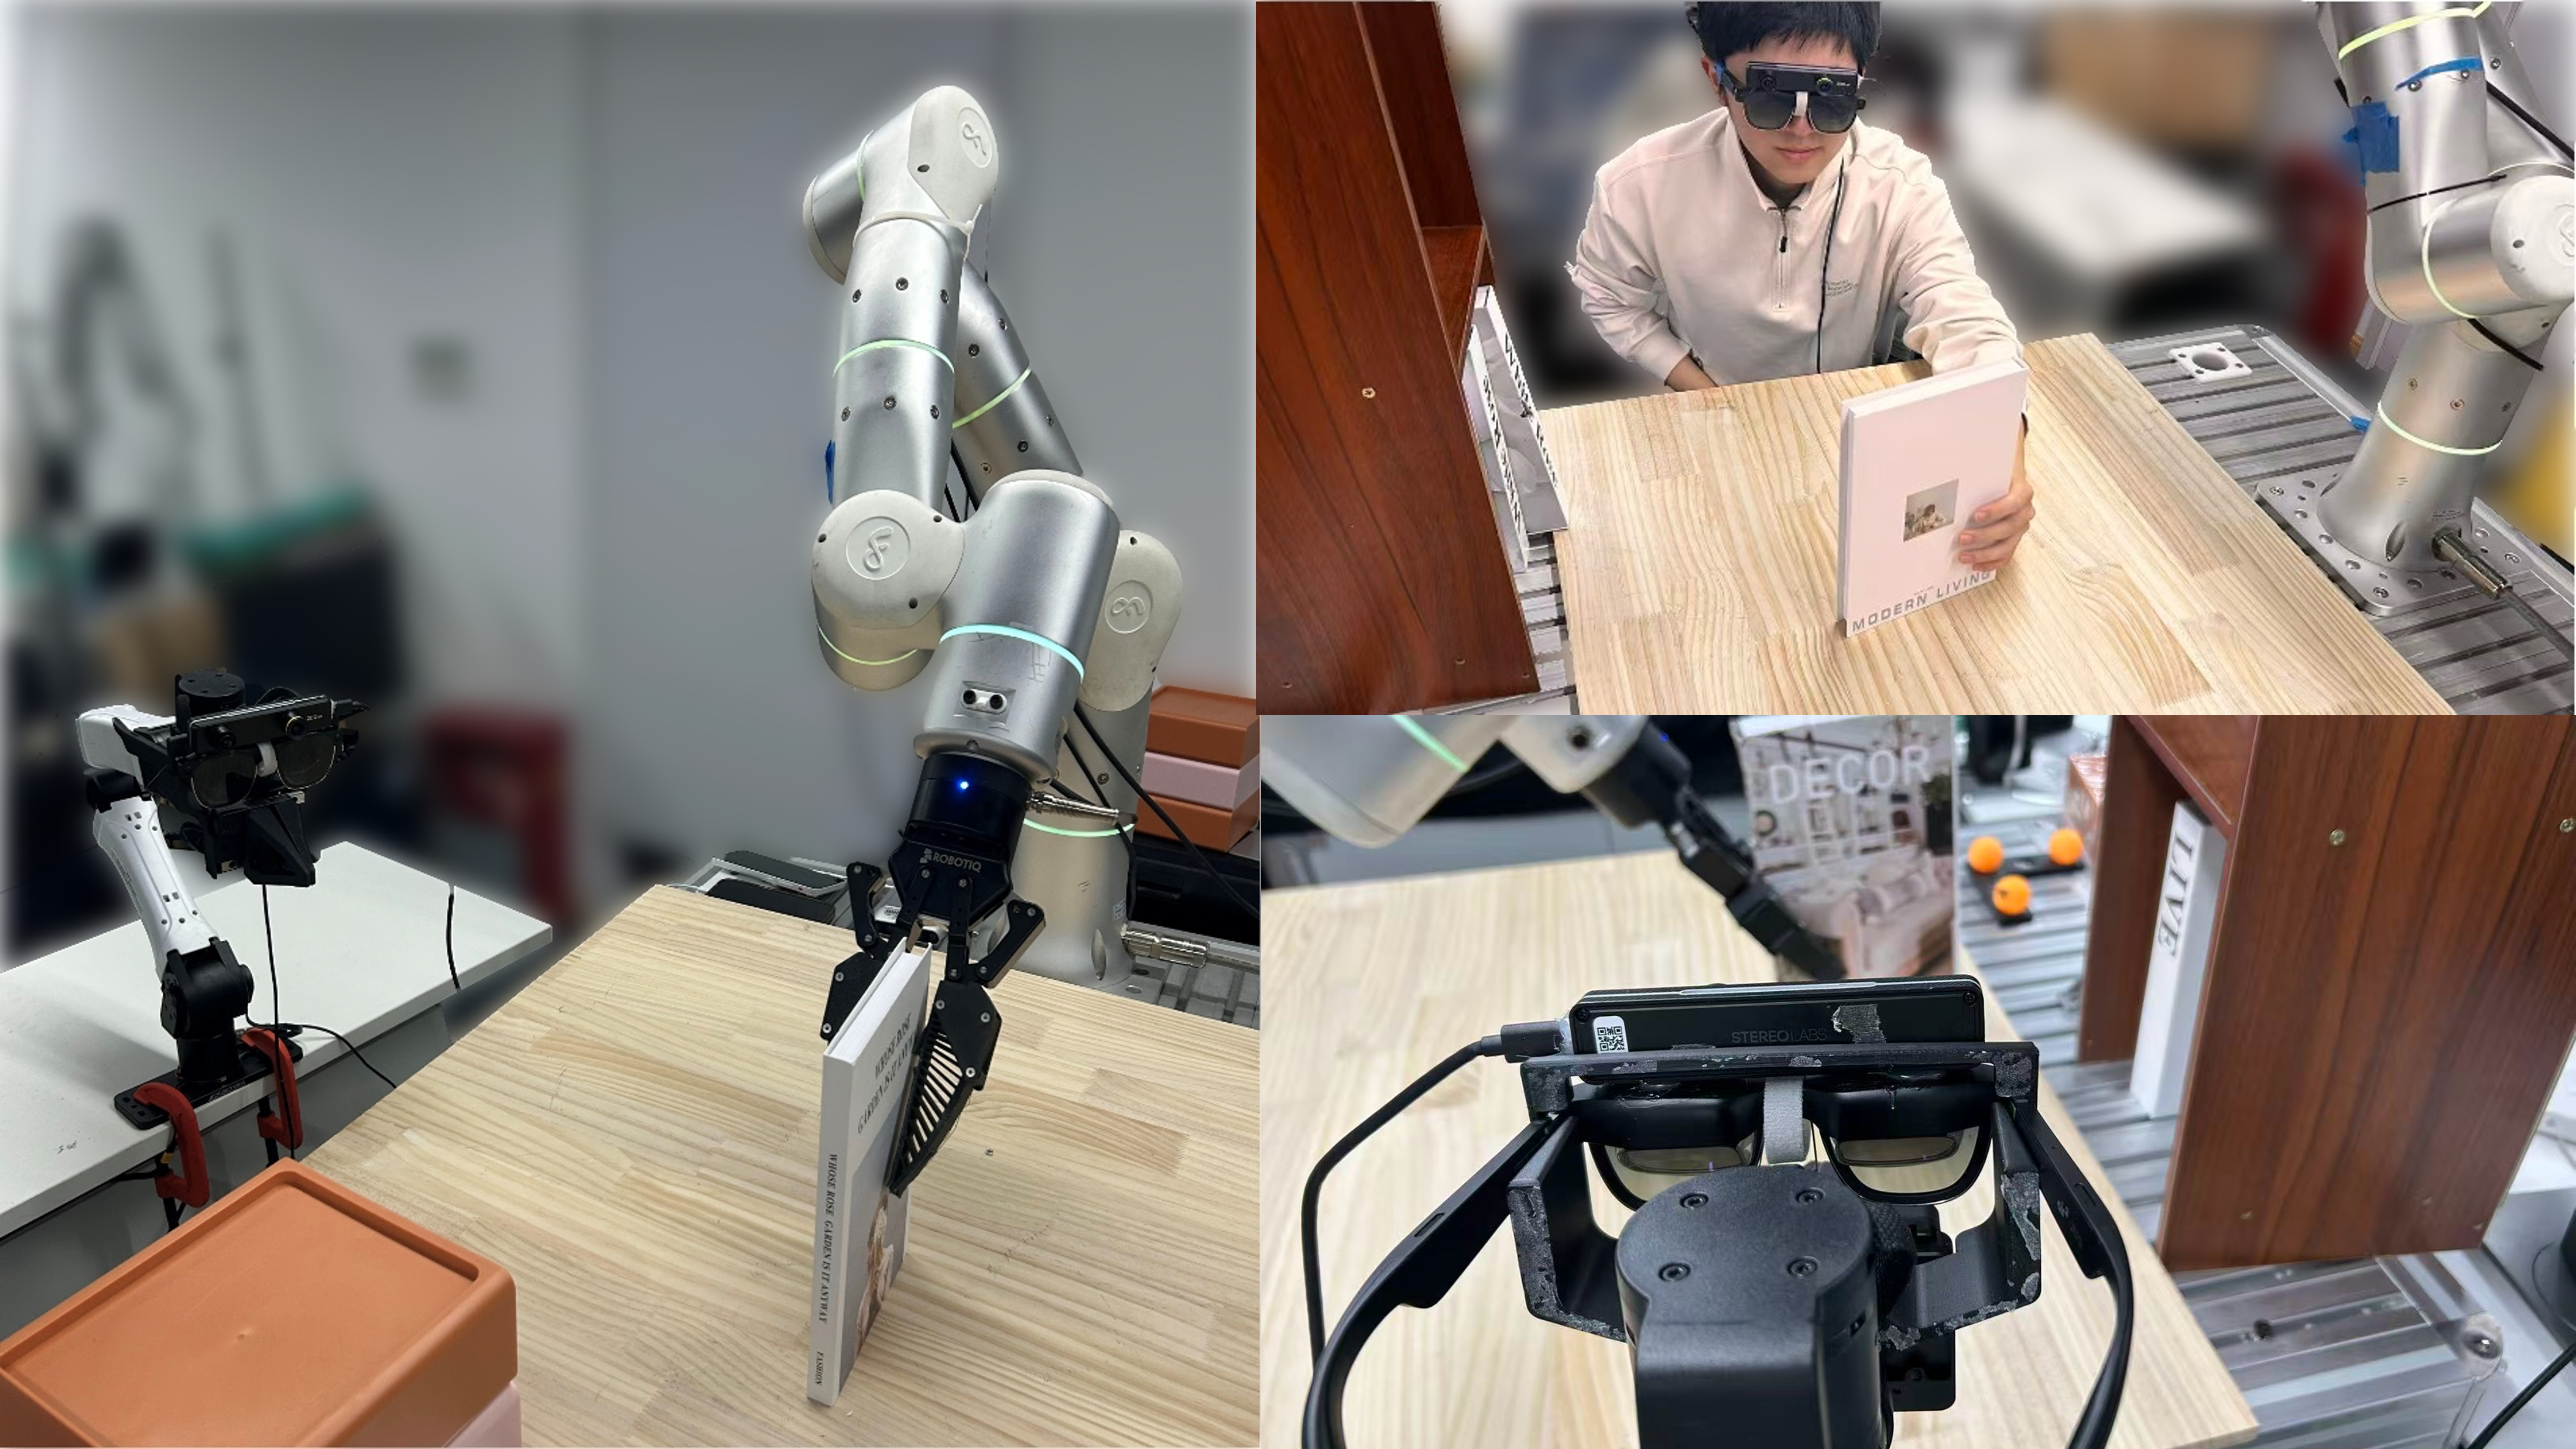 |
ActiveGlasses: Learning Manipulation with Active Vision from Ego-centric Human Demonstration
Yanwen Zou*, Chenyang Shi*, Wenye Yu, Han Xue, Jun Lv, Ye Pan, Chuan Wen†, Cewu Lu† Manuscript, 2026 project page / arXiv ActiveGlasses learns robot manipulation from egocentric human demonstrations with active vision, jointly predicting manipulation and viewpoint motion for cross-embodiment transfer. |
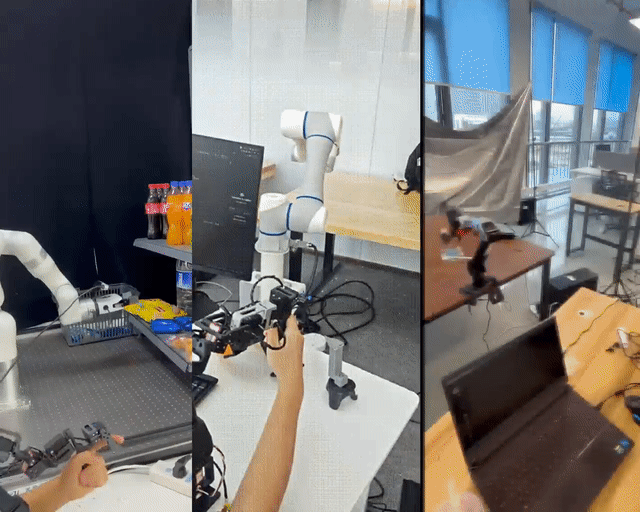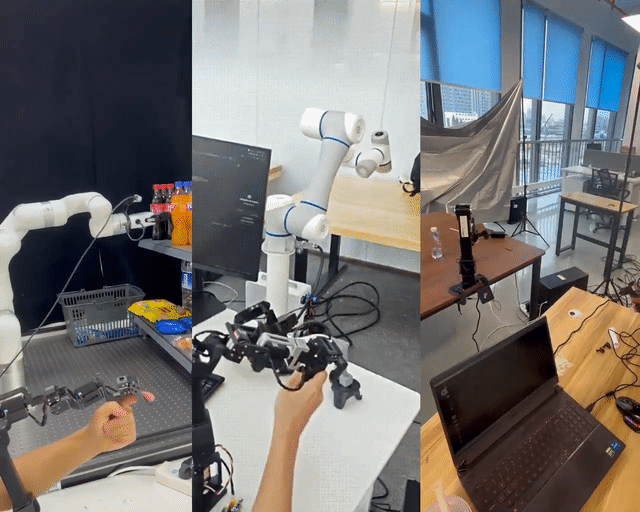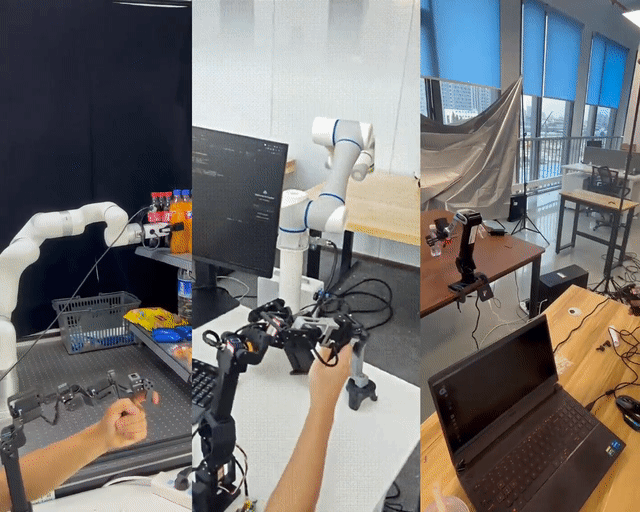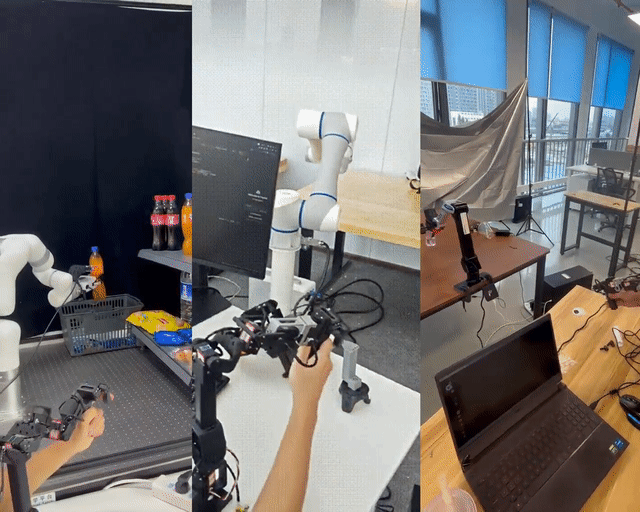 |
U-ARM: Ultra low-cost general teleoperation interface for robot manipulation
Yanwen Zou, Zhaoye Zhou, Chenyang Shi, Zewei Ye, Junda Huang, Yan Ding, Bo Zhao† RSS 2026 RoboData Workshop project page / arXiv U-Arm is a low-cost, universal leader-follower teleoperation system for commercial robot arms, with three hardware configurations for diverse robot platforms. |
Selected Awards and Honors
|